Welcome
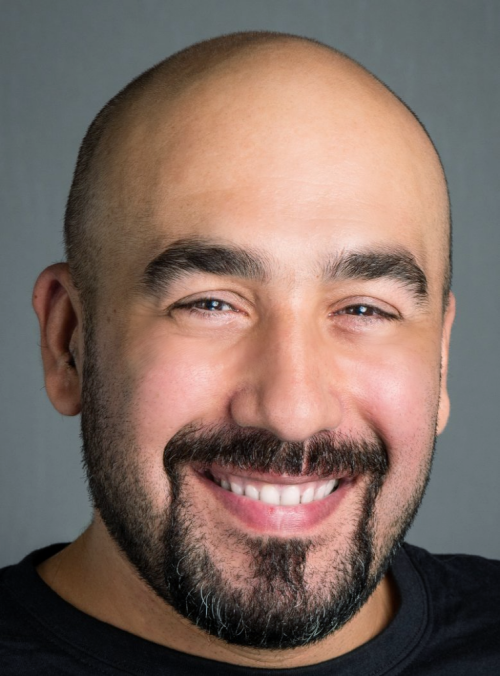 Welcome to my page. I am an Associate Professor, researcher, and educator in autonomous perception, machine learning, and robotic vision at the Australian Institute for Machine Learning (AIML), Adelaide University. My research focuses on developing trustworthy perception systems for autonomous robots, enabling them to operate safely and reliably in complex, uncertain environments. I lead the Embodied AI and Robotic Vision Group and serve as deputy director of the French-Australian CROSSING Lab (CNRS IRL), where we advance research in human–autonomous teaming and the development of intelligent, adaptive robotic systems.
Academic Career
- 2026 - present: Associate Professor, Australian Institute for Machine Learning (AIML), Adelaide University
- 2022 - 2025: Australian Institute for Machine Learning (AIML), University of Adelaide
- 2025 - present Co-Director, CROSSING (French-Australian Laboratory for Human-Autonomous Agents Teaming).
- 2024 - present The AI Theme lead - University of Surrey/University of Adelaide partnership.
- Senior Lecturer, Australian Institute for Machine Learning (AIML), University of Adelaide.
- CI and Project Lead - Centre for Augmented Reasoning (CAR)
- Adjunct Senior Lecturer at the Faculty of Engineering, Queensland University of Technology (QUT).
- 2019-2022 Senior Lecturer - School of Electrical Engineering and Robotics, QUT.
- CI on the following projects:
- Novel autonomous robotic weed control (CRC-P project)
- Robotic Crop Management for Vertical Farming Systems (QUT CAB)
- Intelligent Robotic Systems for Real-Time Asset Management, ARC Research Hub (ITRH)
- CI on the following projects:
- 2020-2022 Chief Investigator - QUT Centre for Robotics (QCR).
- My roles in QCR:
- Co-Lead - Visual learning and understanding program
- Portfolio Lead - Early to Mid-career cohort
- My roles in QCR:
- 2016-2020 The ARC Australian Center for Robotic Vision (ACRV).
- 2019 Chief Investigator
- Deputy project leader - Robotics Vision Evaluation and Benchmarking (ACRV project).
- Deputy program leader - Robot Learning Program (ACRV research program).
- 2018 Associate Investigator
- 2016 Research Fellow
- 2019 Chief Investigator
- 2019-2022 Associate Investigator - QUT Centre for Data Science.
- 2012-2016 Postdoctoral Research Fellow - Science and Engineering Faculty, QUT.
- During my role as a research fellow in QUT I worked on the following projects:
- Autonomous Unsupervised Weed Scouting - Primary project supervisor.
- Semi-automated power pole inspection (CRC-SI project) - Research Fellow.
- RangerBot, a low-cost AUV - Research fellow.
- Human Cues for Robot Navigation (ARC DP project) - Research fellow - PhD thesis supervisor.
- Crown-of-thorns starfish bot (COTSBot) - Perception lead.
- QUT Agricultural Robotics Program - Research fellow - PhD thesis supervisor.
- Lifelong robotic navigation (ARC DP project) - Research fellow - PhD thesis supervisor.
- During my role as a research fellow in QUT I worked on the following projects:
- 2009-2012 Tutor at the University of Lincoln, Lincoln, UK
Awards and Award Finalist
- 2024 Best Paper Honourable Mention, IEEE/CVF Winter Conference on Applications of Computer Vision (WACV 2024).
- 2020 Australian Centre for Robotic Vision award for best-profile raising event in robotics and CV communities.
- 2019 Australian Centre for Robotic Vision award for Best Team Project.
- 2019 Australian Centre for Robotic Vision award for Best Centre Citizen.
- 2019 Certificate of appreciation in recognition of outstanding contribution to the 2019 QUT STEM Camp.
- 2018 Australian Centre for Robotic Vision award for best-profile raising event in robotics and CV communities.
- 2017 Finalist for Best Automation Paper Award, IEEE International Conference on Robotics and Automation (ICRA).
- 2016 Google X challenge, Popular vote award, RangerBot project.
- 2016 Finalist for the Australian Museum Eureka Prizes, Environmental Research.
- 2016 Award for being a Magnet for the School of Electrical Engineering and Computer Science QUT.
- 2015 Vice-Chancellor’s Award, Queensland University of Technology.
Research Degree Completions
PhD completions
- Jad Abou-Chakra (2026) — Co-supervisor
Realtime Structured and Visually Correctable Representations for Robotic Manipulation - Nicolas Chapman (2025) — Co-supervisor
Adapting Vision-Language Models for Robotic Object Detection - Dong Yuan (2025) — Co-supervisor
Ground-to-Aerial Cross-View Image Matching for Robot Localization - Samuel Wilson (2024) — Co-supervisor
Post-hoc Feature-based Out-of-Distribution Detection for Real-World Conditions - Quazi Marufur Rahman (2022) — Primary supervisor
Performance Monitoring of Deep Learning Vision Systems During Deployment - Jesse Haviland (2022) — Co-supervisor
Control Strategies for Reactive Manipulation - Dimity Miller (2021) — Primary supervisor
Epistemic Uncertainty Estimation for Object Detection in Open-Set Conditions - Olga Moskvyak (2021) — Co-supervisor
Learning from Limited Annotated Data for Re-Identification Problem - David Hall (2018) — Primary supervisor
A Rapidly Deployable Approach for Automated Visual Weed Classification without Prior Species Knowledge - Ben Talbot (2018) — Co-supervisor
Integrating Symbolic Spatial Information in Robot Navigation
MPhil completions
- Xiangyu Shi (2025) — Primary supervisor
Domain Adaptation Object Detection for Mobile Robots - Renjie Wu (2024) — Co-supervisor
Towards Pedestrian Safety Augmented Reality System
Workshops and Summer Schools
Conference workshops and challenges
- 2025 · ICLR, 7th Robot Learning Workshop: Towards Robots with Human-Level Abilities.
- 2021 · CVPR, Robotic Vision Scene Understanding Challenge, at the Embodied AI Workshop.
- 2020 · IROS, Reliable Deployment of Machine Learning for Long-Term Autonomy.
- 2020 · ICRA, Scene Understanding and Semantic SLAM: Progress, Applications, and Limitations.
- 2019 · CVPR, The Robotic Vision Probabilistic Object Detection Challenge.
- 2019 · IROS, The Importance of Uncertainty in Deep Learning for Robotics.
- 2018 · ICRA, Long-Term Autonomy and Deployment of Intelligent Robots in the Real World.
- 2018 · CVPR, Real-World Challenges and New Benchmarks for Deep Learning in Robotic Vision.
- 2018 · RSS, New Benchmarks, Metrics, and Competitions for Robotic Learning.
Summer schools
- 2026 — Robotic Vision Summer School.
- 2025 — Robotic Vision Summer School.
- 2024 — Robotic Vision Summer School.
- 2023 — Robotic Vision Summer School.
- 2018 — Workshop, The Great Escape, Robotic Vision Summer School.
Editorial Roles
Conferences
- 2025 — Associate Editor, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
- 2023 — Associate Editor, IEEE International Conference on Robotics and Automation (ICRA).
Journals
- 2018–2019 — Associate Editor, IEEE Robotics and Automation Letters (RA-L).
- 2018 — Associate Editor, IEEE Robotics and Automation Letters special issue on Precision Agricultural Robotics and Autonomous Farming Technologies.
My Research Themes
Autonomous Robots Perception Systems Monitoring and Failure Detection
This theme encompasses research on real-time monitoring and failure detection methods for autonomous robotic perception systems. These studies aim to ensure the robustness, safety, and reliability of autonomous systems, particularly under dynamic and complex environmental conditions.
- Run-Time Monitoring of Machine Learning for Robotic Perception: A Survey of Emerging Trends
- Online Monitoring of Object Detection Performance During Deployment
- FSNet: A Failure Detection Framework for Semantic Segmentation
- Did you miss the sign? A false negative alarm system for traffic sign detectors
Reliable deep learning for robotics: Uncertainty Handling, Out-of-Distribution Detection and Open-Set Recognition in Object Detection
This research theme explores techniques to improve object detection algorithms, particularly in open-set conditions commonly found in robotic vision.
- Dropout sampling for robust object detection in open-set conditions
- Class anchor clustering: A loss for distance-based open set recognition
- Uncertainty for identifying open-set errors in visual object detection
- Predicting Class Distribution Shift for Reliable Domain Adaptive Object Detection
- SAFE: Sensitivity-Aware Features for Out-of-Distribution Object Detection
- Hyperdimensional feature fusion for out-of-distribution detection
Computer Vision and Machine Learning Applications
This research theme focuses on leveraging computer vision and machine learning techniques to tackle various challenging applications.
- Deepfruits: A fruit detection system using deep neural networks
- Robot for weed species plant‐specific management
- Peduncle detection of sweet pepper for autonomous crop harvesting—combined color and 3-D information
- Visual detection of occluded crop: For automated harvesting
- Robotic detection and tracking of Crown-Of-Thorns starfish
Place Recognition and Semantic Mapping in Robotics
This research theme centres on employing Machine Learning methodologies for enhancing robotic navigation capabilities.
- Place categorization and semantic mapping on a mobile robot
- Place recognition with ConvNet landmarks: Viewpoint-robust, condition-robust, training-free
- On the performance of ConvNet features for place recognition
- Long-term experiments with an adaptive spherical view representation for navigation in changing environments
- Multiple map hypotheses for planning and navigating in non-stationary environments
Teaching
Adelaide University
- 2026 - Present
- Computer Science Honours Research Project - Supervision
- Master Capstone Project - Supervision
The University of Adelaide
- 2022 - 2025:
- COMP_SCI_1102 - Object-Oriented Programming - Course Coordinator/Lecturer (2022,2023).
- COMP_SCI_3317 - Using Machine Learning Tools (2022,2023)
- COMP_SCI_7327 - Concepts in Artificial Intelligence & Machine Learning - Course Coordinator/Lecturer (2022).
QUT
- 2016-2021:
- EGB439 - Advanced Robotics - Unit Coordinator/Lecturer (2017-2021).
- CAB202 - Microprocessors and Digital Systems - Unit Coordinator/Lecturer (2016-2021).
- EGB419 - Mechatronics Design 3 - Lecturer (2020).
Publications
| Full and up-to-date list found here |
Deepfruits: A fruit detection system using deep neural networks I Sa, Z Ge, F Dayoub, B Upcroft, T Perez, C McCool sensors 16 (8), 1222
On the performance of convnet features for place recognition N Sünderhauf, S Shirazi, F Dayoub, B Upcroft, M Milford 2015 IEEE/RSJ international conference on intelligent robots and systems …
Place recognition with convnet landmarks: Viewpoint-robust, condition-robust, training-free N Sünderhauf, S Shirazi, A Jacobson, F Dayoub, E Pepperell, B Upcroft, … Robotics: Science and Systems XI, 1-10
Place categorization and semantic mapping on a mobile robot N Sünderhauf, F Dayoub, S McMahon, B Talbot, R Schulz, P Corke, … 2016 IEEE international conference on robotics and automation (ICRA), 5729-5736
Evaluation of features for leaf classification in challenging conditions D Hall, C McCool, F Dayoub, N Sunderhauf, B Upcroft IEEE Winter Conference on Applications of Computer Vision (WACV), 797-804
Dropout sampling for robust object detection in open-set conditions D Miller, L Nicholson, F Dayoub, N Sünderhauf IEEE International Conference on Robotics and Automation (ICRA)
An adaptive appearance-based map for long-term topological localization of mobile robots F Dayoub, T Duckett 2008 IEEE/RSJ International Conference on Intelligent Robots and Systems …
Long-term experiments with an adaptive spherical view representation for navigation in changing environments F Dayoub, G Cielniak, T Duckett Robotics and Autonomous Systems 59 (5), 285-295
Peduncle detection of sweet pepper for autonomous crop harvesting—combined color and 3-D information I Sa, C Lehnert, A English, C McCool, F Dayoub, B Upcroft, T Perez IEEE Robotics and Automation Letters 2 (2), 765-772
Robot for weed species plant‐specific management O Bawden, J Kulk, R Russell, C McCool, A English, F Dayoub, C Lehnert, … Journal of Field Robotics
Probabilistic object detection: Definition and evaluation D Hall, F Dayoub, J Skinner, H Zhang, D Miller, P Corke, G Carneiro, … IEEE Winter Conference on Applications of Computer Vision 2020
Visual detection of occluded crop: For automated harvesting C McCool, I Sa, F Dayoub, C Lehnert, T Perez, B Upcroft 2016 IEEE International Conference on Robotics and Automation (ICRA), 2506-2512
Evaluating Merging Strategies for Sampling-based Uncertainty Techniques in Object Detection D Miller, F Dayoub, M Milford, N Sünderhauf IEEE International Conference on Robotics and Automation (ICRA)
Vision-only autonomous navigation using topometric maps F Dayoub, T Morris, B Upcroft, P Corke IEEE/RSJ International Conference on Intelligent Robots and Systems November …
Varifocalnet: An iou-aware dense object detector H Zhang, Y Wang, F Dayoub, N Sünderhauf Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern …
Robotic detection and tracking of Crown-Of-Thorns starfish F Dayoub, M Dunbabin, P Corke IEEE/RSJ International Conference on Intelligent Robots and Systems, Hamburg …
Robot navigation using human cues: A robot navigation system for symbolic goal-directed exploration R Schulz, B Talbot, O Lam, F Dayoub, P Corke, B Upcroft, G Wyeth 2015 IEEE International Conference on Robotics and Automation (ICRA), 1100-1105
Multiple map hypotheses for planning and navigating in non-stationary environments T Morris, F Dayoub, P Corke, G Wyeth, B Upcroft IEEE International Conference on Robotics and Automation (ICRA), 2014 1 …
Find my office: Navigating real space from semantic descriptions B Talbot, O Lam, R Schulz, F Dayoub, B Upcroft, G Wyeth 2016 IEEE International Conference on Robotics and Automation (ICRA), 5782-5787
Semantics for Robotic Mapping, Perception and Interaction: A Survey S Garg, N Sünderhauf, F Dayoub, D Morrison, A Cosgun, G Carneiro, … arXiv preprint arXiv:2101.00443